Career
Twelve years, real systems
2025 — Present
Rekise Marine
Vice President, Robotics
Leading autonomous navigation for marine robots across both surface vessels (USV) and underwater vehicles (UUV) — spanning applications in survey, surveillance, and inspection across open-water environments.
2023 — 2025
Ola Electric
Associate Director, Perception
Spearheaded perception for autonomous vehicles, robotics, and two-wheelers, leading 7 research engineers. End-to-end data-driven navigation, multi-camera BEV generation, SLAM, and a full two-wheeler ADAS stack with forward collision warning and adaptive cruise control.
2022 — 2023
Samsung R&D
Research Lead
Led 16 engineers across robotics, computer vision, and deep reinforcement learning. Built robot re-localization using 2D LiDAR, human detection and tracking, RL-based coverage path planners, and an RL agent for software memory leak detection.
2016 — 2022
Intel Labs, Bangalore
Research Scientist
Six years building distributed swarm robotics, multi-robot SLAM, and event camera-based visual inertial odometry. Led a team including two PhD holders. Gordy Award nominee — Intel Labs' highest honour. Published at ICRA, ISSCC, IROS, and MFI.
2014 — 2016
Uurmi Systems
Senior Computer Vision Engineer
Led a team of five engineers and four university students on an autonomous car project — visual odometry, SLAM, path planning, multi-sensor fusion, and object tracking.
2011 — 2014
IIT Kharagpur
Founder & Head, AGV Research Group
Founded and led a 30-student autonomous ground vehicle team across departments. Designed end-to-end navigation for the Intelligent Ground Vehicle Competition (IGVC), Michigan, 2012–14.
Signature work
Selected projects
A handful of the systems I'm most proud of — spanning swarms, event-based vision, learned planning, and field robotics.
Uurmi Systems & IIT KGP · 2011–2016
Autonomous Car — Self-Driving on Indian Roads
One of my most significant career contributions — building a full self-driving stack for Indian road conditions. Led teams developing lane detection, visual odometry, SLAM, multi-sensor fusion, path planning, and object tracking. The work began with the AGV group's IGVC campaigns at IIT Kharagpur and matured into a university-industry autonomous car program at Uurmi Systems.
▶ Watch demos on the AGV YouTube channel →
Intel Labs · 2017–2019
Distributed Autonomous Swarm Robots
A fully distributed swarm where ground robots and drones coordinate without any central server — each making local decisions from shared state and dynamic anchor selection. Demonstrated as a working PoC; the work led to several granted US patents and was featured at ISSCC 2019 on a custom 22nm CMOS robot SoC.
Intel Labs · 2019–2022
AVIO — Event-Based Visual Inertial Odometry
Visual odometry built on event cameras — neuromorphic sensors firing at microsecond resolution. AVIO fuses asynchronous event streams with IMU data for low-latency localization in fast-motion and low-light conditions where conventional cameras fail. Best Paper, IEEE CONECCT 2023.
Intel Labs · 2019–2021
KB-RRT — Kinematic Path Planner
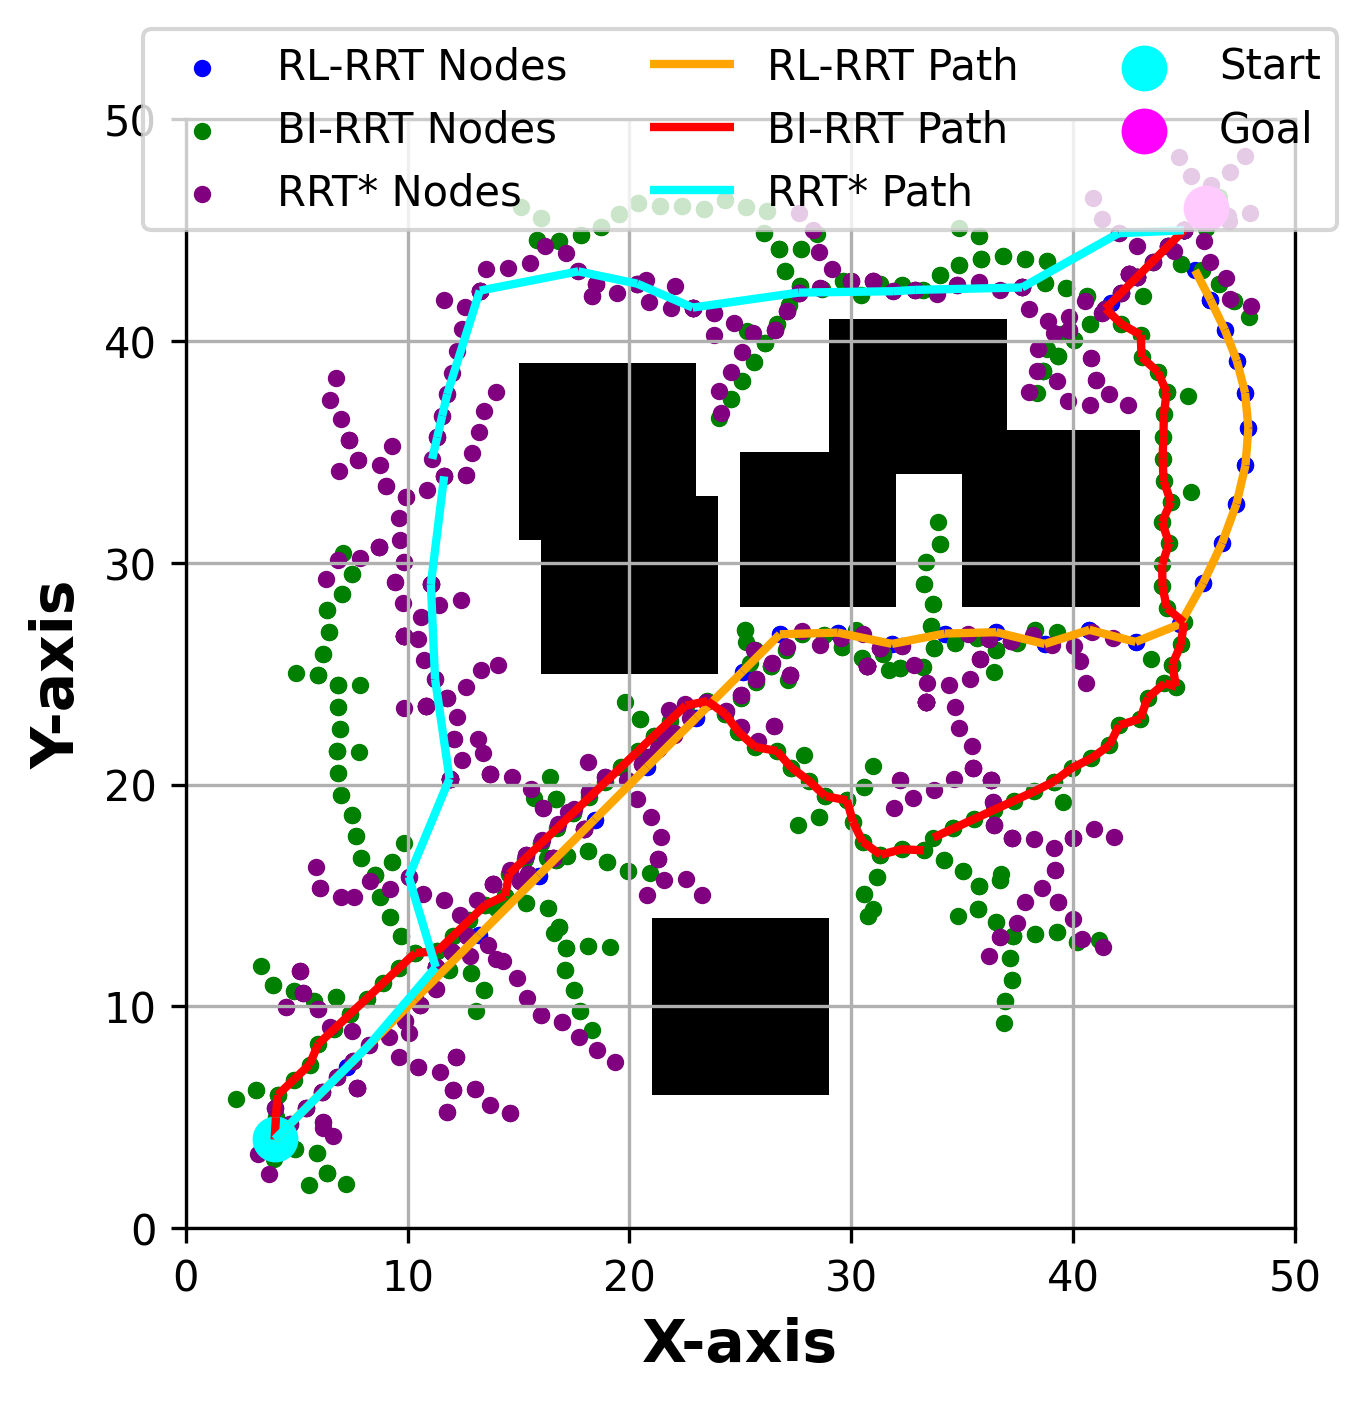
A bi-directional RRT that respects real robot kinematic constraints, generating smooth, executable trajectories rather than geometric paths. Extended to PG-RRT using Gaussian Mixture Models for probabilistic environment representation. Published at ICRA 2019 and IROS 2021.
IIT Kharagpur · 2025
RL-BiRRT — Reinforcement Learning Path Planning
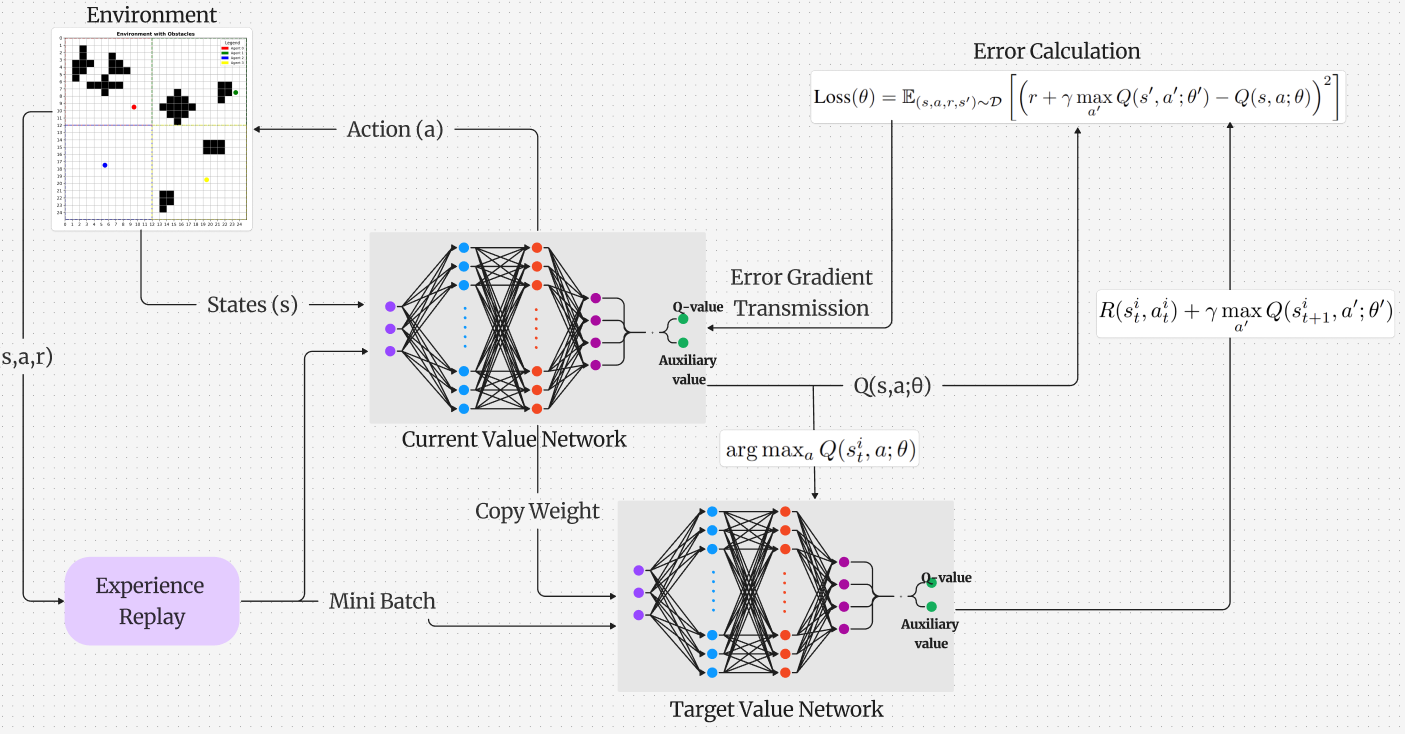
A reinforcement-learning-driven framework for intelligent path planning that learns to guide the bi-directional RRT search — producing faster, smarter trajectories than classical sampling-based planners. Published at ICAR 2025.
IIT Kharagpur · 2025
Deep RL Coverage Path Planner
Deep reinforcement learning agents trained to solve coverage planning — ensuring a robot covers every point in an unknown environment with minimal overlap. Extended to multi-agent coordination (MultiAgent-DeepQ) where agents divide territory and explore unknown environments together. Published at ICAR 2025.
Ola Electric · 2023–2025
Multi-Camera Bird's Eye View
Fused feeds from cameras around a two-wheeler into a unified top-down representation of the surroundings — enabling accurate object detection, lane awareness, and safe navigation for autonomous two-wheelers at production scale.
IIT Kharagpur · PhD Thesis
3D Underground Mine Mapping Robot
A prototype autonomous mobile robot that maps GPS-denied underground mines in 3D using 6D SLAM — fusing LiDAR, IMU, and cameras for robust pose estimation in featureless, dust-filled tunnels. Sponsored by ISRO. The work that started it all.
Intellectual property
Granted patents — US & India
Press & writing
In the spotlight
The Scholars' Avenue · IIT Kharagpur Campus Newspaper
Know Your Research Group — AGV
A feature on the Autonomous Ground Vehicle Research Group at IIT Kharagpur, which I founded — a multidisciplinary student team building self-driving vehicles and competing at the Intelligent Ground Vehicle Competition (IGVC), Michigan.
Get in touch
Open to collaboration
Currently exploring my next venture in autonomous systems. Open to founding, advisory and deep-tech collaboration — or just a conversation about where robotics is headed.